
One of the real pleasures of being an Early-Stage Researcher within CASCADE is the way secondments are designed to push you somewhere you might never have gone on your own. From April to July 2026, mine took me to the Nimbus Research Centre at Munster Technological University, where I spent three months working alongside researchers in robotics, Human–Robot Interaction, conversational AI, agentic systems and trustworthy AI. My PhD at University College Cork normally keeps me firmly in the world of texts and language. When I started with CASCADE, I did not imagine that any part of it would involve standing beside a robotic arm, watching it decide what somebody had meant.
Robotic Glossolalia
My starting point at Nimbus was the inTRUSTED project, a TU RISE initiative concerned with a deceptively difficult question: what does it take for people to trust the technologies they increasingly have to live and work with? Its approach is deliberately broader than technical security alone. Drawing on the idea of a Living Lab, inTRUSTED brings technological development into real-world, interdisciplinary settings where researchers, users and other stakeholders can participate in shaping how systems are designed, evaluated and ultimately trusted.
That immediately raised an interesting question for me as someone coming from language and computational modelling. If a Living Lab is ultimately about humans and technologies working together in a shared ecosystem, then language is not simply an interface layered on top of the technology. It is one of the places where that relationship is negotiated. We use language to tell systems what we want, to explain what went wrong, to ask for clarification, to communicate uncertainty and, ultimately, to decide whether we trust what a system is doing.
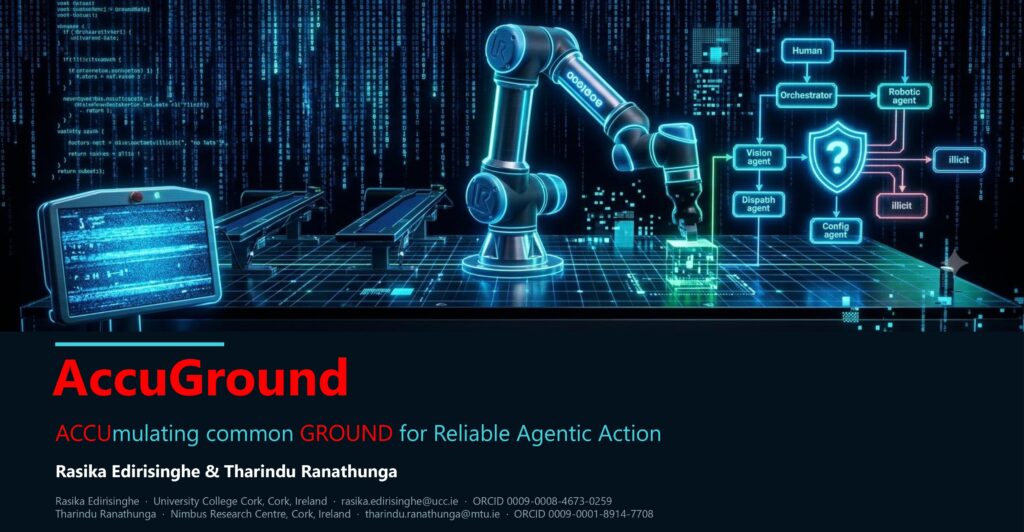
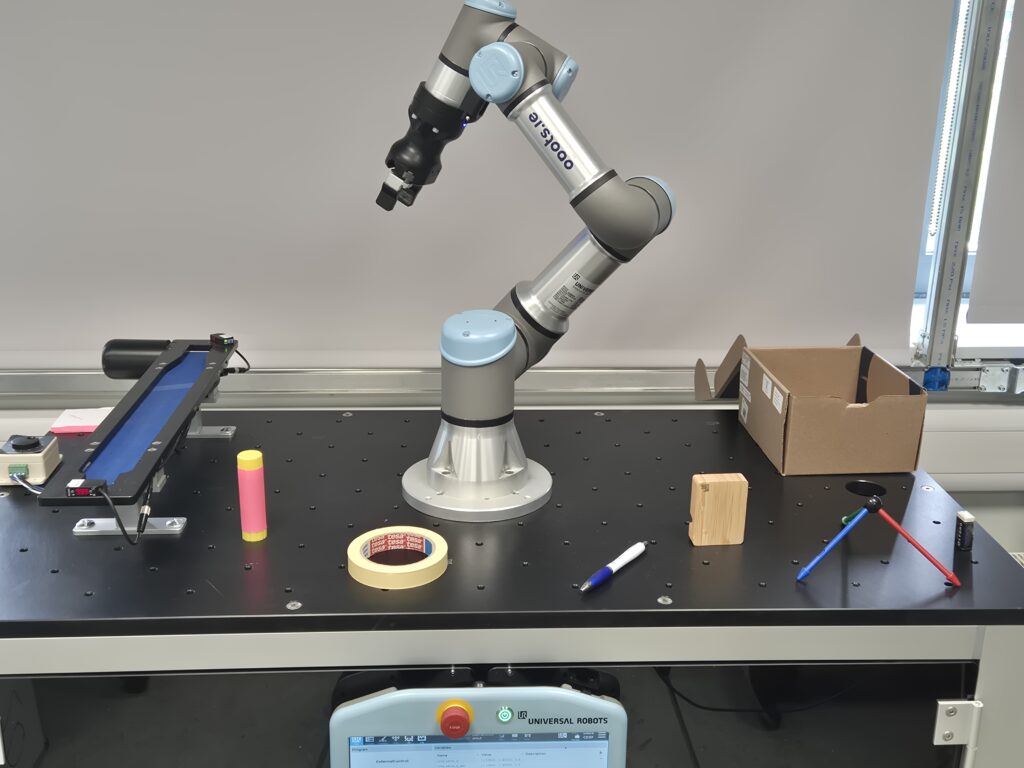
At Nimbus, that question became tangible through a conversational agentic robotic platform built around a collaborative robot arm. You give the system an instruction in ordinary language, and that instruction passes through several AI components (or agents) before the robot eventually acts. Suddenly, ideas such as trust, safety and reliability were no longer abstract qualities of a digital system. They depended, in part, on something much more basic: whether the human and the machine had actually understood one another.
In my usual work, a misreading produces a bad result in a table. Here, a misreading could produce a gripper closing on the wrong object. That difference sharpened one question very quickly: if I tell a system to do something, how do I know that what it eventually does is still grounded in what I actually meant?
The question sounds almost too obvious to ask. It became considerably less obvious once we looked at what happens in between. A modern AI system does not interpret an instruction only once. One component interprets it and passes something onward; another receives and interprets that representation in turn. As information is reshaped from one stage to the next, so too can the system’s representation of the user’s intent, until eventually that interpretation becomes an action in the world in which the system is embedded.
Following an Instruction Through the Machine
We set about pulling that journey apart by assembling a corpus of instructions, running them through the live system and recording what happened at every hand-off along the way. Some instructions were straightforward. Some expressed the same intention in different ways, allowing us to see whether phrasing alone changed the outcome. Others were deliberately underspecified. By the end, we had a collection of instructions and traces documenting, step by step, how meaning travelled through the system and what became of it.
The traces showed many places where an intended meaning could shift along the way. But the moment that genuinely changed how I thought about the work was much simpler than any of the numbers we collected.
Imagine saying: “Pick that one.”
A person hearing this immediately understands that “that one” must refer to something. If they cannot see what you are pointing at, they will not quietly select an object and hope for the best. They will look at you and ask: “Which one?”
That entirely ordinary piece of conversational repair turned out to be at the centre of the problem. We were seeing cases where the system encountered a reference that had never actually been established and nevertheless found a plausible way to continue. The output could sound perfectly sensible. It could even produce the correct action. But the system had filled in a missing piece of the instruction for itself — and then acted as though that information had come from the user.
What Counts as Established?
This was the point at which a secondment at a robotics centre looped unexpectedly back into formal linguistics. There is a long tradition in pragmatics concerned with precisely these situations. We do not communicate in isolated sentences; conversations accumulate a history of references, assumptions, corrections and shared information. One way formal pragmatics describes this is through the idea of common ground — the information that has become sufficiently established between participants for a conversation to move forward.
The question was therefore no longer simply how do we make the system interpret the command correctly? It became: what has actually been established firmly enough for the system to act on?
That distinction became the foundation of the work that emerged from the secondment. We called it AccuGround — ACCUmulating common GROUND for Reliable Agentic Action. The idea is much simpler than the name. An AI system(llm) can interpret. It can suggest. It can make a very good guess. But before that guess becomes an action, the system should be able to account for where the load-bearing pieces of information came from. If it cannot, the most intelligent thing available to it may be to ask.
That caution comes with an interesting price. Our experiments suggested that the approach could prevent nearly all of the specific failures we were targeting, but they also showed that caution is not free: a system that refuses to quietly fill gaps will sometimes ask a question where another system would simply proceed. I have come to like that tension. A great deal of current effort goes into making AI systems more capable, more fluent and more willing to answer. As these systems move from producing language to doing things, knowing when to say “I don’t have enough information yet” may itself be a form of capability.
The Same Problem, in Reverse
CASCADE is built around questions of meaning across different environments, approached through different periods, languages, texts and computational methods. My own PhD asks what happens to meaning as language is transformed between texts: a quotation is rewritten, an allusion survives with almost none of its original wording, or the same idea surfaces differently depending on context. At Nimbus, I found myself studying a different kind of transformation — what happens to meaning as an instruction passes between a human, a language model and a machine. In my usual work, I am trying to recover meaning that remains present even when the words have changed. At Nimbus, I was confronting almost the inverse problem: how do we stop a machine from adding meaning that was never there in the first place?
That connection is probably the most valuable thing I am bringing back from the secondment. Robotics and agentic AI took me well outside my usual research space, but underneath the unfamiliar machinery was a familiar problem: language is contextual, interpretation depends on evidence, and a plausible reading is not necessarily one the context supports. As AI systems move from interpreting language to acting on it, that distinction becomes much harder to ignore. The challenge is not only to make machines better at finding meaning, but also better at recognising when there is not yet enough meaning to act on. In that sense, some of our newest technologies may still depend on something fundamental to communication itself: Meaning does not exist in words alone, but in what we establish between us.
And all we have to do is keep talking…..
Rasika Edirisinghe is a Visiting Lecturer at the University of Ruhuna, Sri Lanka and Sri Lanka Telecom Training Centre, specializing in Data Science, fundamentals of AI, and Business Intelligence. With an M.Sc. in Business Analytics from Robert Gordon University and over five years of industry experience across various data science roles, Rasika brings a wealth of practical and theoretical knowledge to academia. His research interests span NLP, Machine Learning, and Deep Learning, with a focus on sentiment reason mining and healthcare analytics. Rasika’s recent work includes developing a Twitter Sentiment Reason Mining Framework for the US healthcare industry. As a Data Analyst at EFL Global.llc, he has implemented data-driven solutions for automating business processes across global operations
CASCADE is a collaboration between University College Cork, University of Sheffield, University of Helsinki, KU Leuven, and Universität des Saarlandes. Funded by Horizon Europe under the Marie Skłodowska-Curie Actions (MSCA) Doctoral Networks and the UKRO.